
Satellite compass vs gyrocompass accuracy comparison
Satellite Compass vs Gyrocompass Accuracy Comparison: The Number on the Spec Sheet Is Not the Whole Story
Title: Satellite Compass vs Gyrocompass Accuracy Comparison: What the SC90 and SC120 Actually Bring to the Bridge
The comparison usually starts with a number. A gyrocompass settles to 0.05 degrees RMS static. A satellite compass lists 0.2 or 0.4 degrees RMS. The conclusion writes itself: the gyro is more accurate.
That conclusion is not wrong. It is just incomplete. Because the static number on a datasheet tells you what happens when the vessel is sitting still in calm water with a perfectly settled sensor. It does not tell you what happens during a turn, after a power interruption, at high latitude, or on the fifth year of service when the gyro sphere is due for replacement.
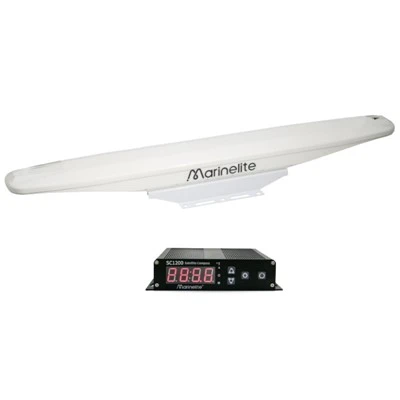
We build the SC90 and SC120 satellite compasses. Both carry MED certification as Transmitting Heading Devices under IMO MSC.116(73). The SC120 is specified at 0.2 degrees RMS heading accuracy. The SC90 is specified at 0.4 degrees RMS. Neither number beats a high-end gyrocompass in a static test. But the comparison that matters on a working vessel is not the static test.
The Gyrocompass Baseline: What Its Accuracy Actually Costs
A good spinning-mass gyrocompass reaches static accuracy in the range of 0.05 to 0.1 degrees secant latitude, with dynamic accuracy around 0.2 to 0.4 degrees secant latitude under Scorsby and intercardinal motion conditions. A fiber-optic gyro can push the static figure lower still. These are real numbers from real instruments, and they represent decades of engineering refinement.
But those numbers come with conditions. The gyrocompass needs hours to settle before it reaches that accuracy. It needs latitude and speed input to apply corrections. The spinning mass or the fiber-optic sensing coil is a precision assembly that wears or degrades over time. The gyro sphere is a service item, not a lifetime component. And at high latitude, the secant latitude term in the accuracy specification grows, which means the achievable accuracy degrades as the vessel moves toward the poles.
None of this makes the gyrocompass a bad instrument. It makes it a specific instrument with a specific dependency profile. It does not need a radio signal. It does not care about satellite geometry. When the GNSS goes away, the gyrocompass keeps producing heading. That autonomy is the reason it remains the regulatory baseline for SOLAS vessels.
What the SC90 and SC120 Change About the Comparison
The SC90 and SC120 do not try to be gyrocompasses. They are multi-GNSS carrier-phase heading sensors. They resolve heading from the phase difference between two antennas, tracking GPS, GLONASS, Galileo, and BeiDou simultaneously. The SC120 holds 0.2 degrees RMS. The SC90 holds 0.4 degrees RMS. Both deliver that accuracy within two minutes of power-on.
Two minutes. That is not a trivial difference. A gyrocompass that needs two to four hours to settle is a gyrocompass that must be kept running continuously, even in port, even when the vessel is not moving. A satellite compass that settles in under two minutes can be powered down between watches or during maintenance and brought back to full accuracy before the vessel clears the breakwater.
The turn rate specification is equally relevant to the dynamic comparison. Both units track turns at 90 degrees per second. That is well beyond the IMO high-speed craft requirement and well beyond what a conventional gyrocompass is typically specified to follow. In a sea-trial comparison of dual-antenna GNSS heading against a gyrocompass, the dynamic standard deviation was ±0.18 degrees, with a correlation of 0.9. The GNSS solution was not lagging behind the gyro during motion. It was tracking the same heading change within a fraction of a degree.
The Part Where the Signal Disappears
Here is the honest limitation. The SC90 and SC120 depend on GNSS. If the satellite signals are lost, the carrier-phase heading solution is lost with them. That is not a software bug. It is the physical principle of the instrument.
This is the point where the gyrocompass comparison becomes a discussion about consequences rather than degrees. A gyrocompass without GNSS still produces heading. A satellite compass without GNSS does not. The question for a vessel operator is not whether the satellite compass is more accurate in ideal conditions. It is whether the operating profile can tolerate a heading source that depends on an external radio signal.
For a vessel with a gyrocompass already installed as the primary regulatory heading source, the SC90 or SC120 can serve as a high-accuracy secondary source, a fast-starting backup, and a cross-check against gyro drift. The satellite compass does not replace the gyrocompass in that architecture. It complements it, and in some cases it outperforms it on specific metrics-startup time, turn tracking, and high-latitude stability, because there is no north-seeking mechanism to weaken as latitude increases.
Maintenance, Cost, and the Five-Year View
The accuracy comparison cannot be separated from the cost of keeping that accuracy over the life of the vessel.
A gyrocompass is a maintenance item. The gyro sphere is typically replaced on a multi-year cycle. Annual servicing is common. A fiber-optic gyro reduces the maintenance burden but carries a higher purchase price. The SC90 and SC120 have no mechanical parts. There is no sphere to replace, no bearings to service, no settling mechanism to overhaul. The maintenance cost over a decade is fundamentally lower. The purchase price is lower as well.
That cost difference is not an argument that the satellite compass is "better." It is an argument that the two instruments occupy different positions in a vessel's heading architecture. A satellite compass is cheaper to buy and cheaper to keep. A gyrocompass is more expensive on both counts but provides autonomous heading that does not depend on an external signal. The vessel's route, regulatory obligations, and redundancy requirements decide which trade-off is appropriate.
The Certification Frame That Keeps the Comparison Honest
Both the SC90 and SC120 carry MED certification and type approval as Transmitting Heading Devices. That means they have been tested against the accuracy, environmental, and interface requirements of IMO MSC.116(73) and the relevant IEC standards. The SC120's 0.2-degree RMS specification is not a marketing figure. It is a tested performance claim within the THD framework.
But the THD standard is not the gyrocompass standard. A satellite compass certified as a THD can feed heading to radar, ECDIS, AIS, and autopilot. It cannot satisfy a carriage requirement that specifically calls for a gyrocompass. The regulatory distinction exists because the two instruments have different dependency profiles, not because one is inherently more accurate than the other.
That distinction is the reason the most practical bridge architecture on many vessels is not "satellite compass versus gyrocompass." It is both. The gyrocompass provides the regulatory baseline and the autonomous fallback. The SC90 or SC120 provides a fast-settling, high-accuracy heading source that can be used to monitor the gyrocompass, to feed systems that benefit from its specific characteristics, and to maintain heading awareness during the periods when the gyro is settling or being serviced.
What the SC120's 0.2 Degrees Actually Means in Practice
A 0.2-degree RMS heading accuracy on a satellite compass is not automatically equivalent to a 0.2-degree gyrocompass specification, because the error spectra are different. A spectral analysis of satellite compass errors has noted that the devices perform at a level of about 1 degree overall and behave in a way that is not directly comparable to a gyro or magnetic compass in terms of error frequency content. That means the autopilot filtering that works well for a gyro heading source may need adjustment for a GNSS heading source. The number alone does not tell you how the integrated bridge system will behave.
What the SC120's specification does tell you is that the carrier-phase solution is tight enough to feed radar overlay and ECDIS without visible misalignment, tight enough to serve as a cross-check against gyro drift, and tight enough to support autopilot steering in conditions where a 0.4-degree source would be marginal. The SC90's 0.4-degree specification occupies a similar position one step down the accuracy ladder, appropriate for vessels where the heading requirement is less demanding but the benefits of fast startup and zero mechanical maintenance still apply.
Neither unit is a drop-in replacement for a gyrocompass on a vessel that requires one. Both are instruments that make the comparison more nuanced than a single number. The gyro wins on autonomy. The SC90 and SC120 win on startup time, turn tracking, maintenance cost, and-within their dependency profile-accuracy that overlaps with the gyrocompass range rather than sitting comfortably below it.
That is the comparison worth having. Not which number is smaller, but which instrument's failure modes and dependencies match the vessel's actual operating reality.